



3D occupancy mapping
Home
3D occupancy mapping
EXPLORE
Millimeter Wave Radar Solutions
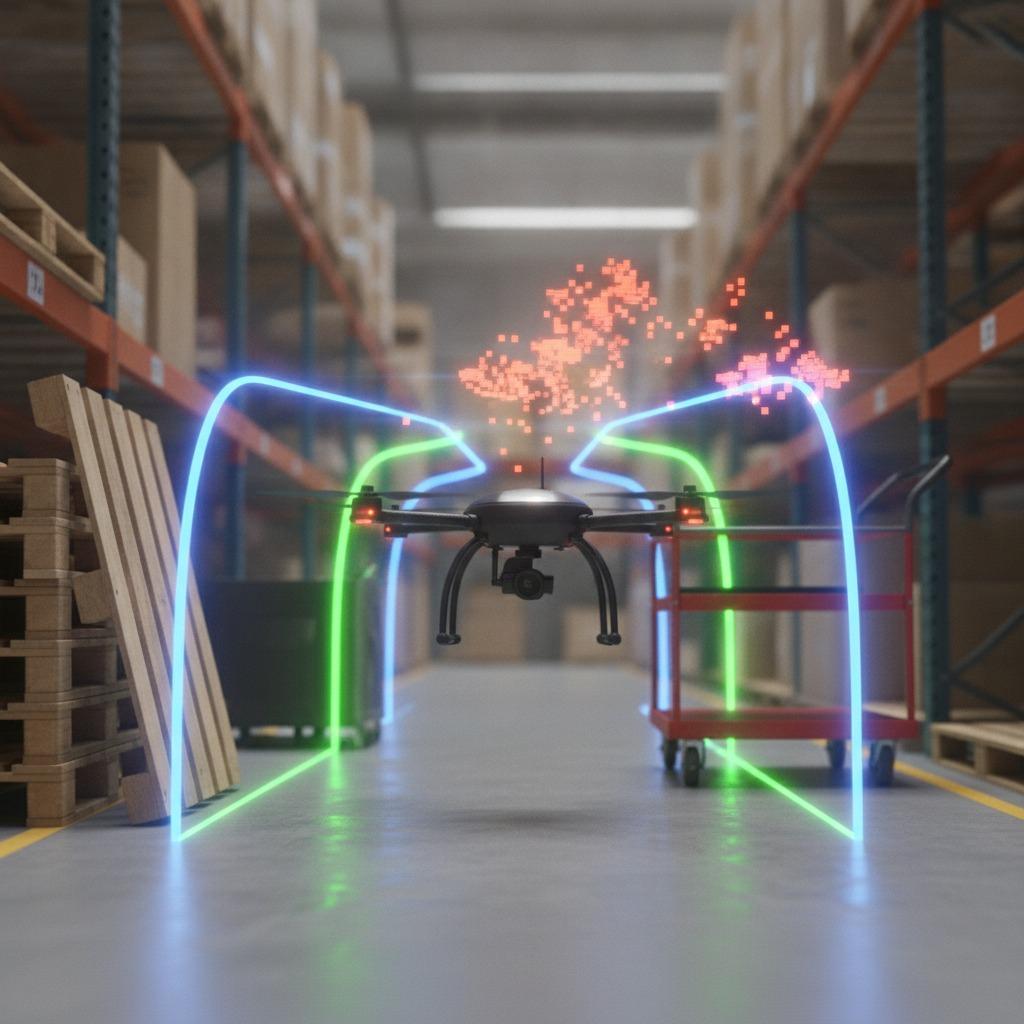
1. Why real-time obstacle avoidance has become a buying criterion, not a nice-to-have 2. What real-time obstacle avoidance is actually doing 3. Quick comparison: what each function contributes 4. How buyers should judge a solution, not just a feature 5. Common failure points in the field 6. What to ask before you buy 7. Practical buyer advice 8. FAQ: a few questions that come up in sourcing reviews 9. Choosing a safer route to deployment
 Ningbo Linpowave

1. Why 3D Occupancy Mapping Has Become a Practical Drone Autonomy Tool 2. What the Map Actually Tells the Flight System 3. Where 3D Occupancy Mapping Fits Best 4. Quick Buyer Takeaways 5. Common Design Choices and Their Trade-Offs 6. Frequent Mistakes Buyers Make 7. What Good Procurement Questions Sound Like 8. FAQ: A Few Questions That Come Up Early 9. Practical Next Step
Ningbo Linpowave
1. Why real-time obstacle avoidance matters in field robotics and UAV operations 2. The core problem: plans age faster than real environments 3. How the main avoidance stack usually works 4. What buyers should compare before choosing a system 5. Common mistakes that slow adoption 6. Practical buyer advice 7. FAQ: short answers buyers usually want 8. What a good next step looks like
Ningbo Linpowave